The library
Articles
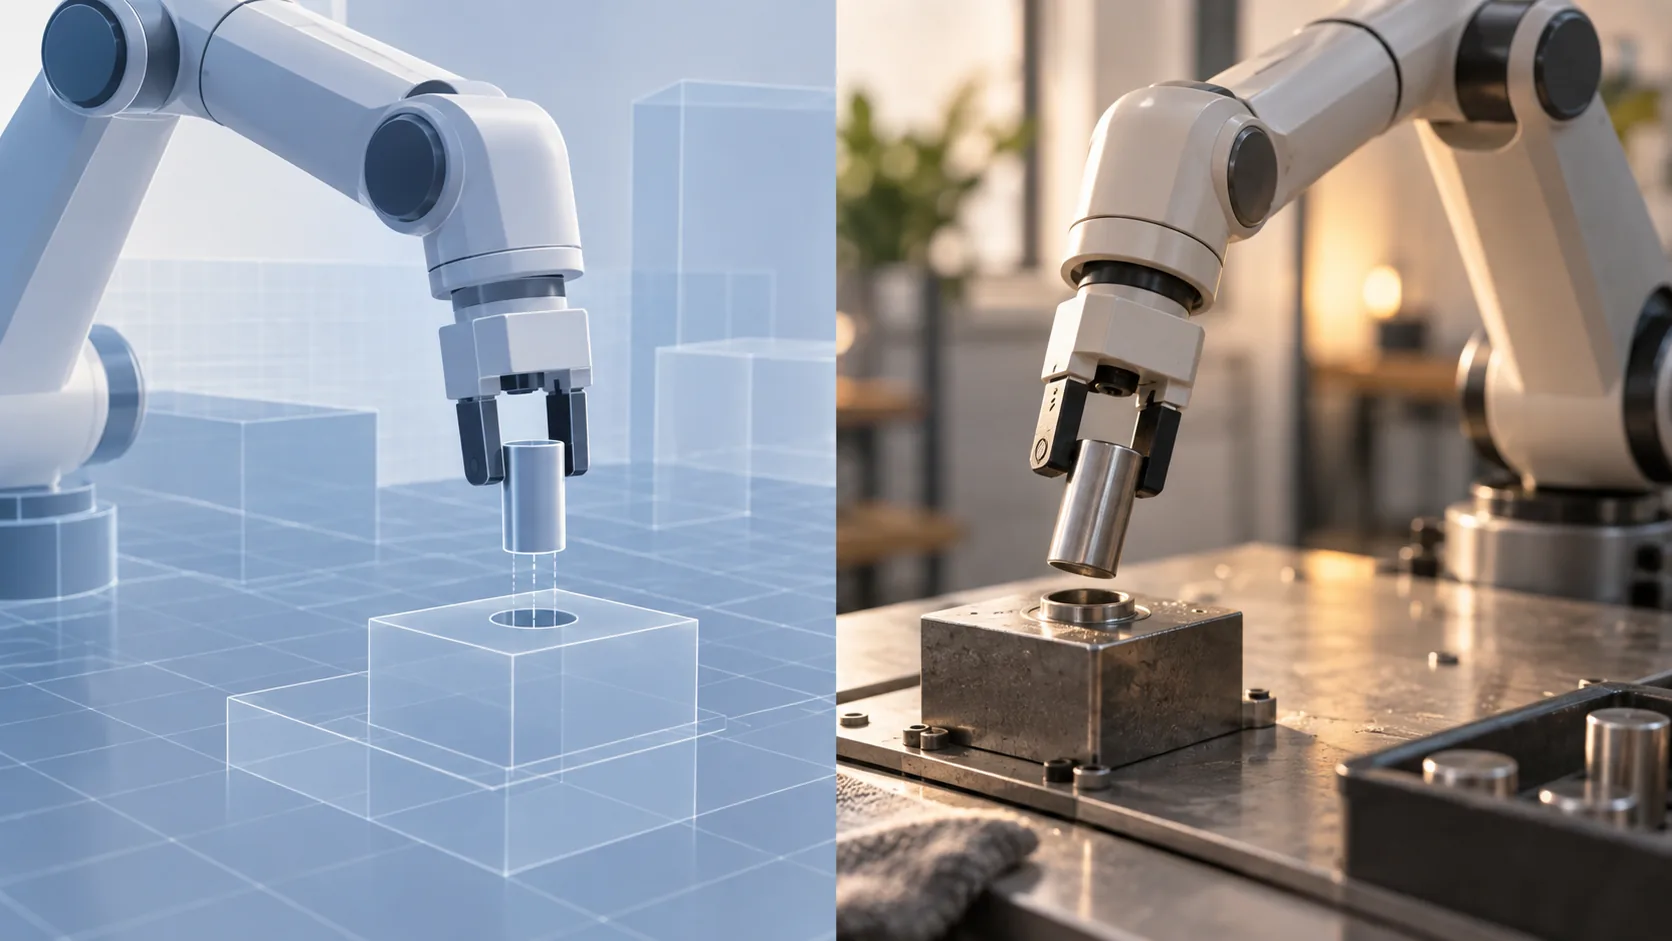
Why can a robot trained in simulation fail in the real world?
Why simulator observations and physics can differ from hardware, with varied simulation, human correction and physical learning as research approaches.
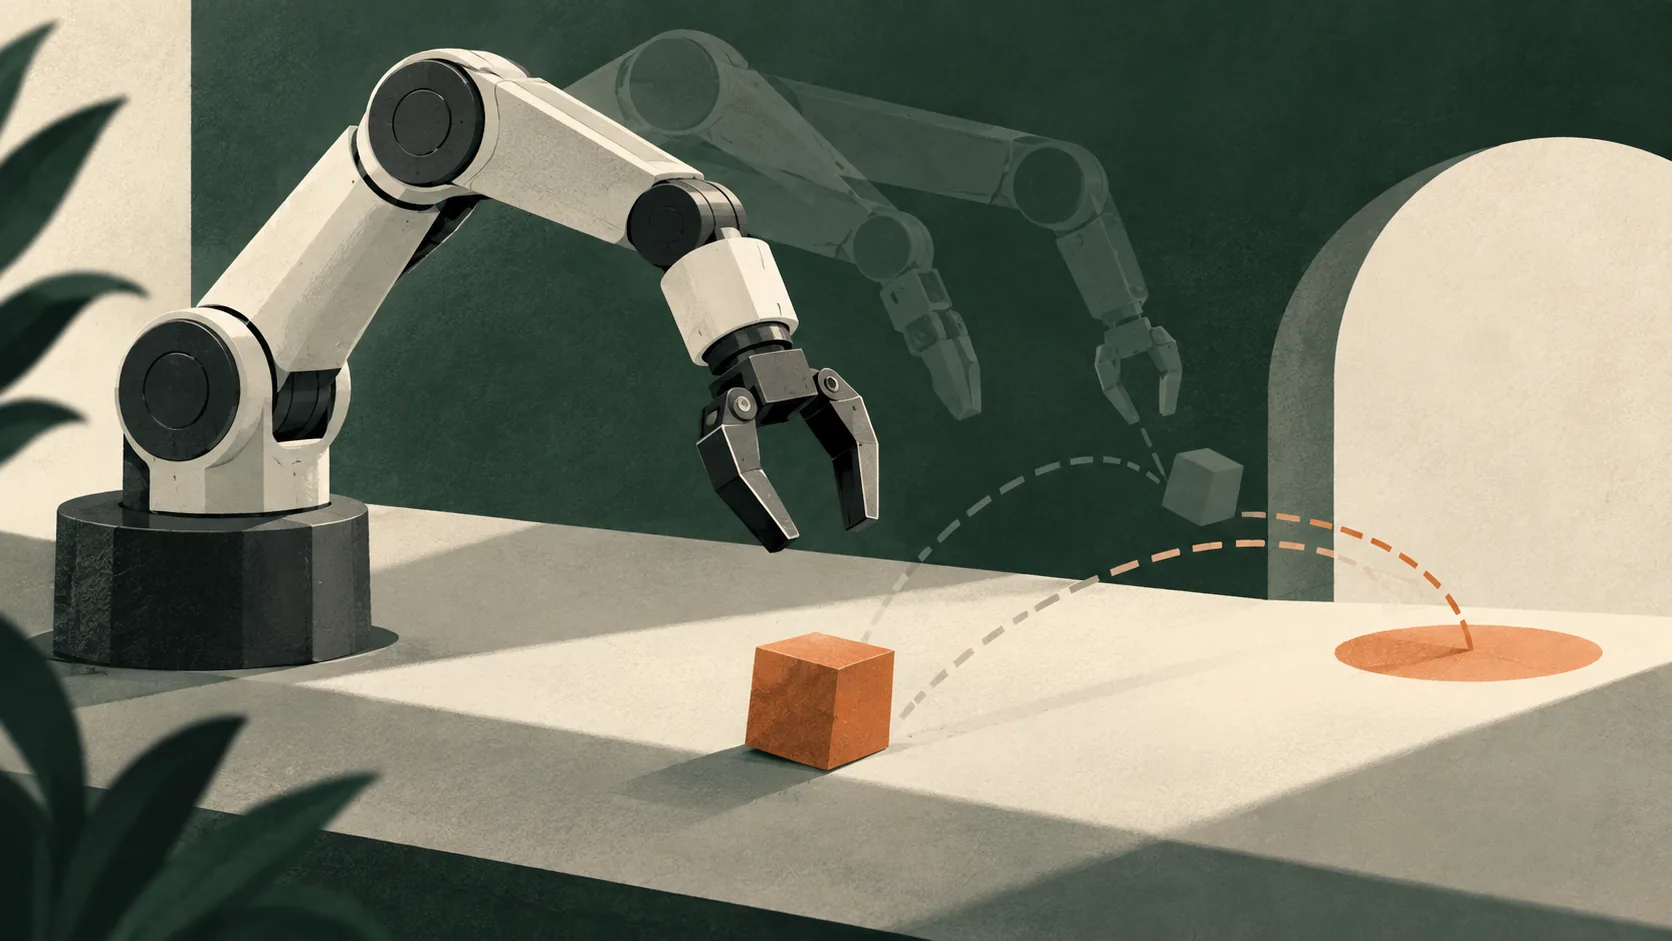
How do we test whether a robot can recover after an error?
How RoboRecover reconstructs simulated recovery points, compares clean-start and recovery results on LIBERO, and limits what the rates can show.