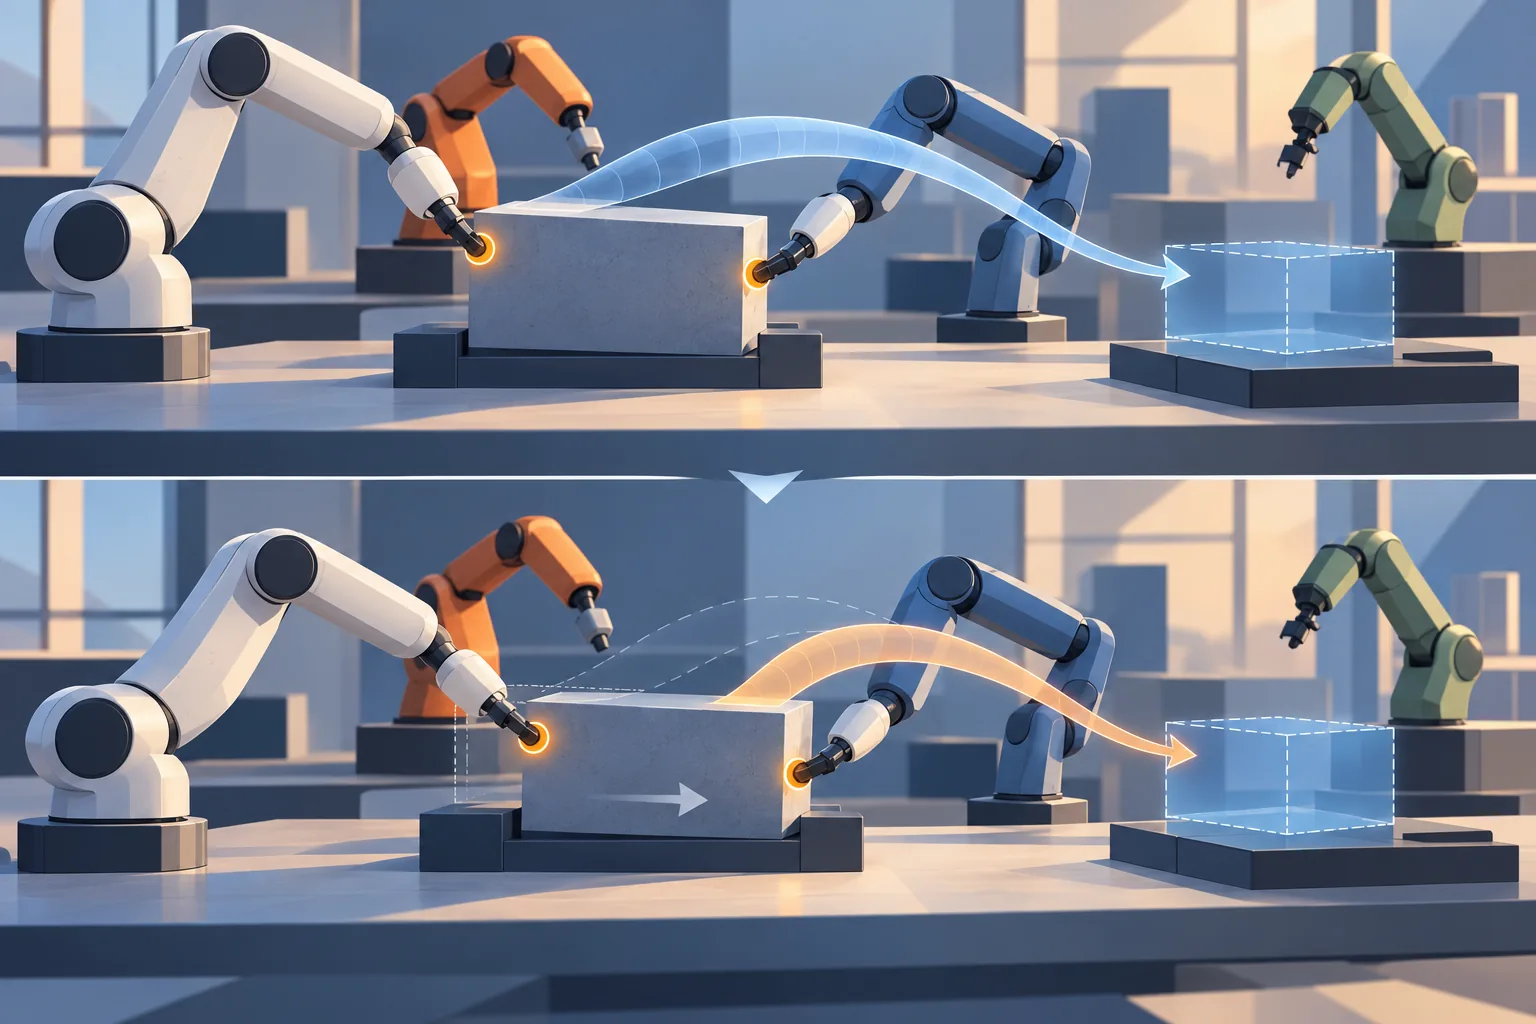
Separating a Robot Task’s Effect From Its Actor
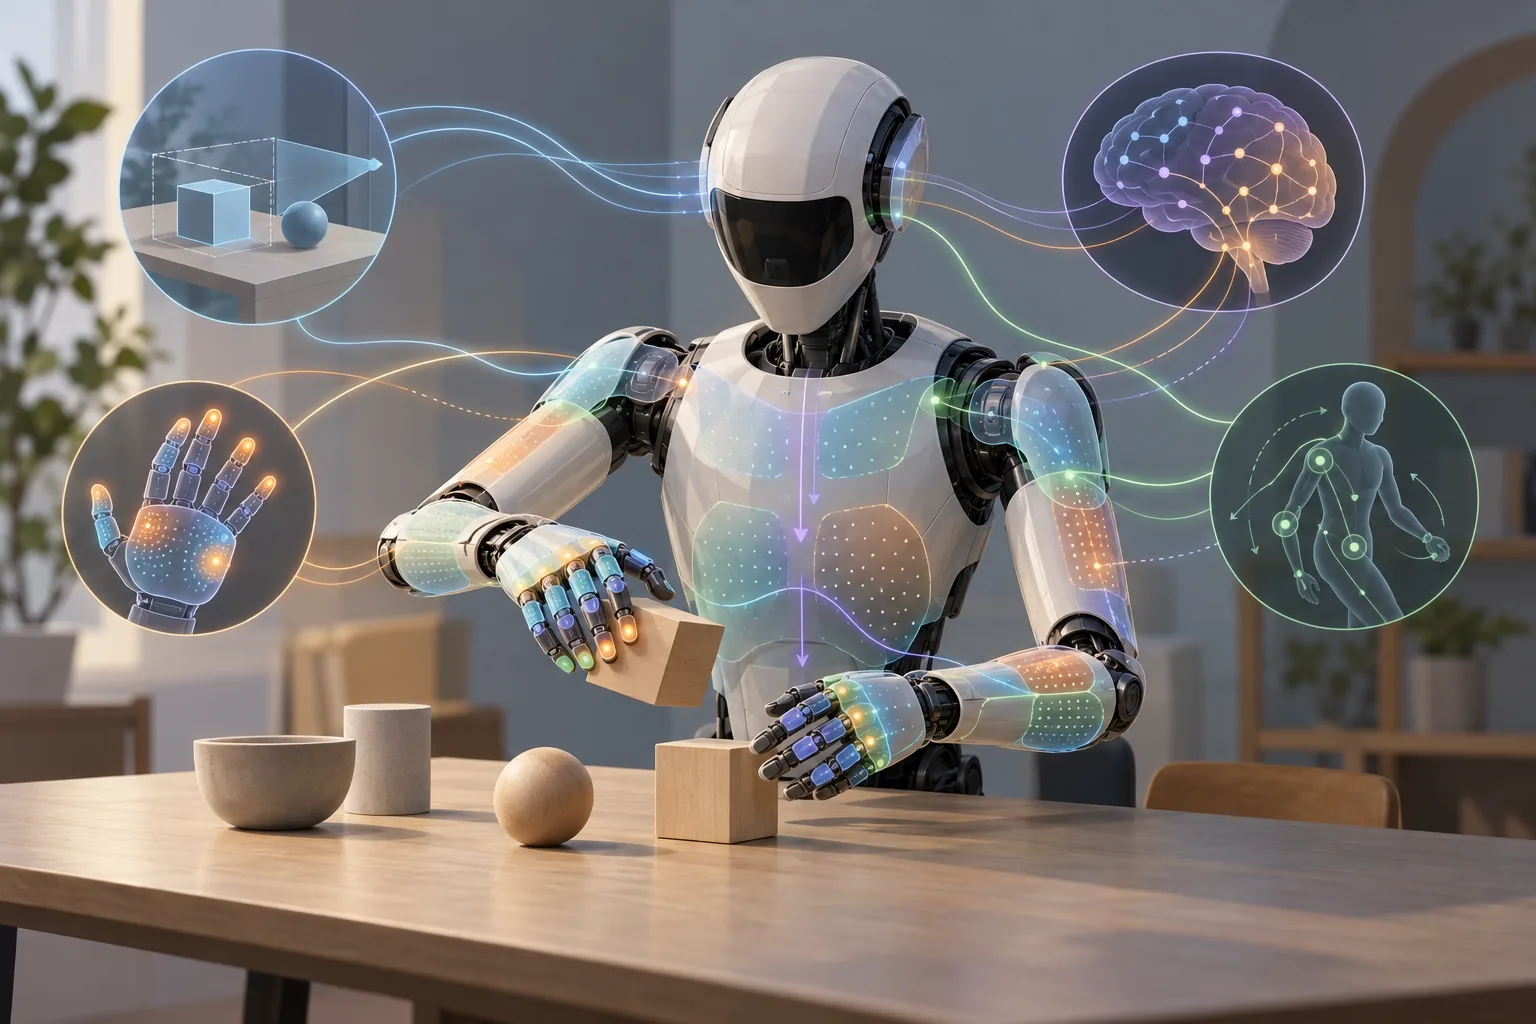
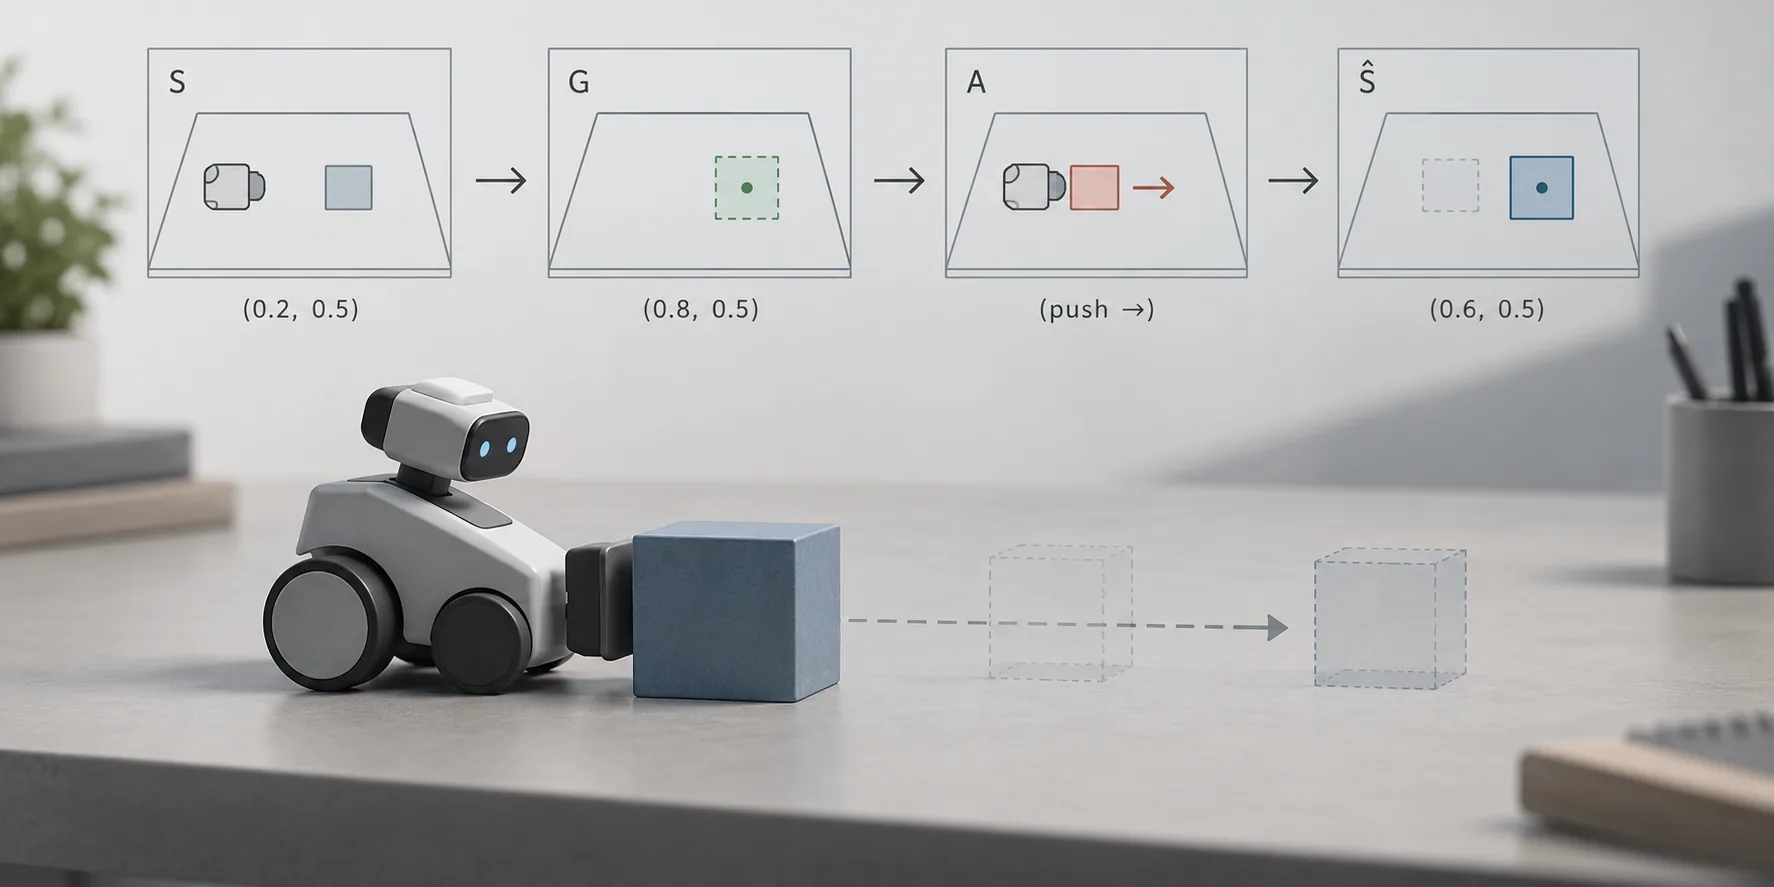
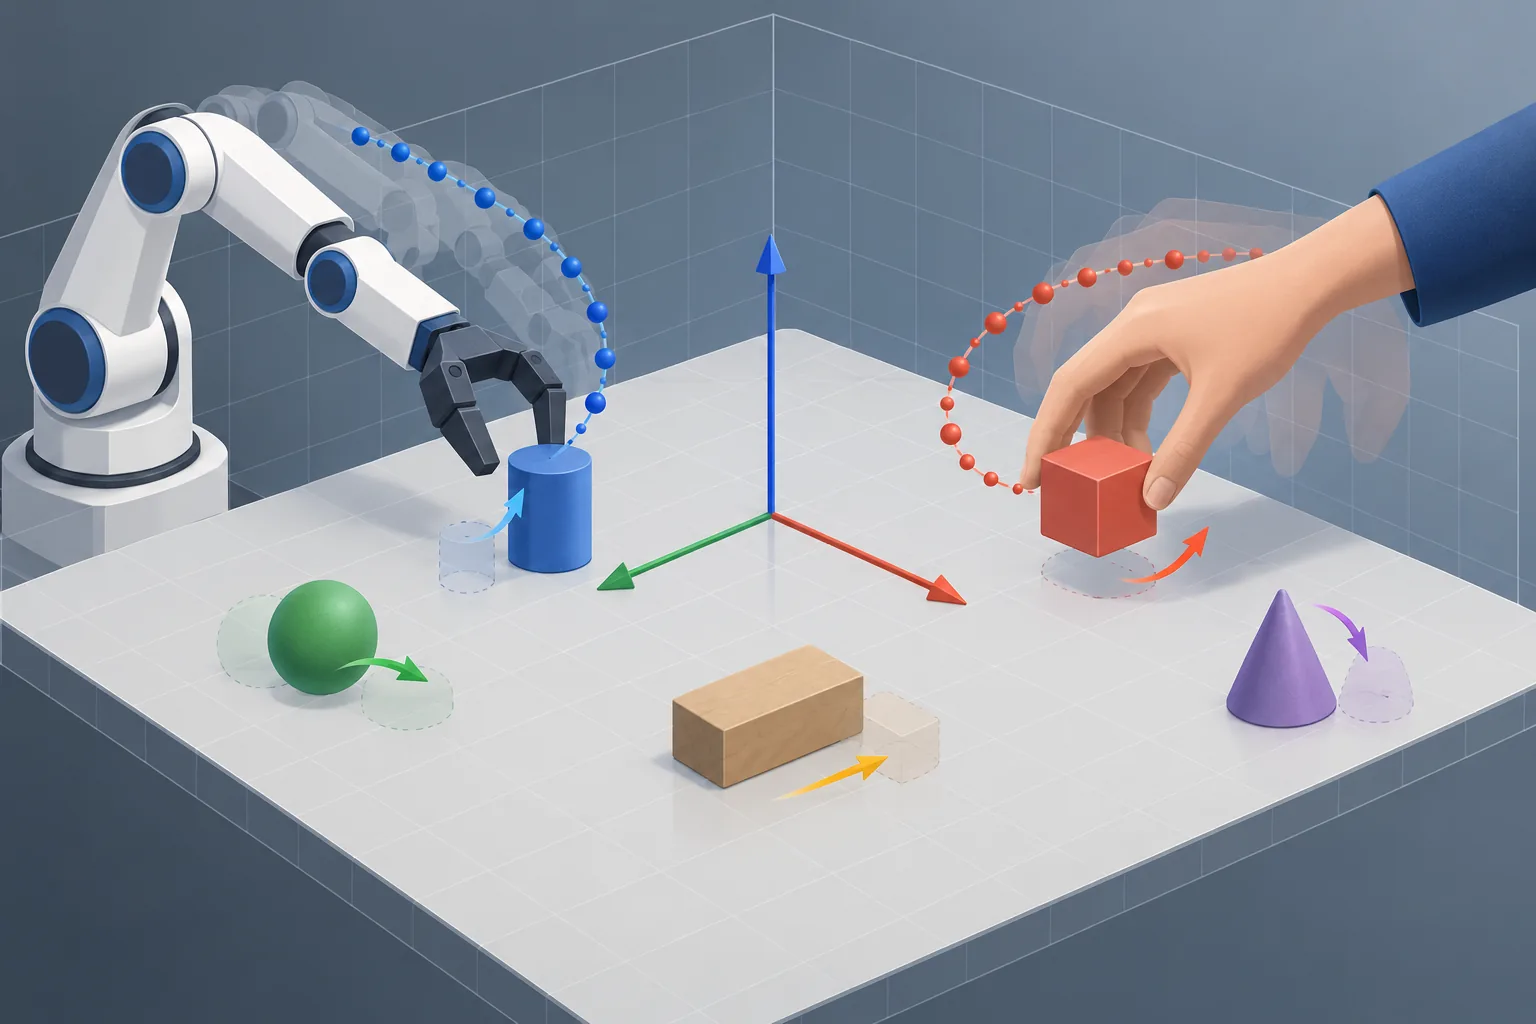
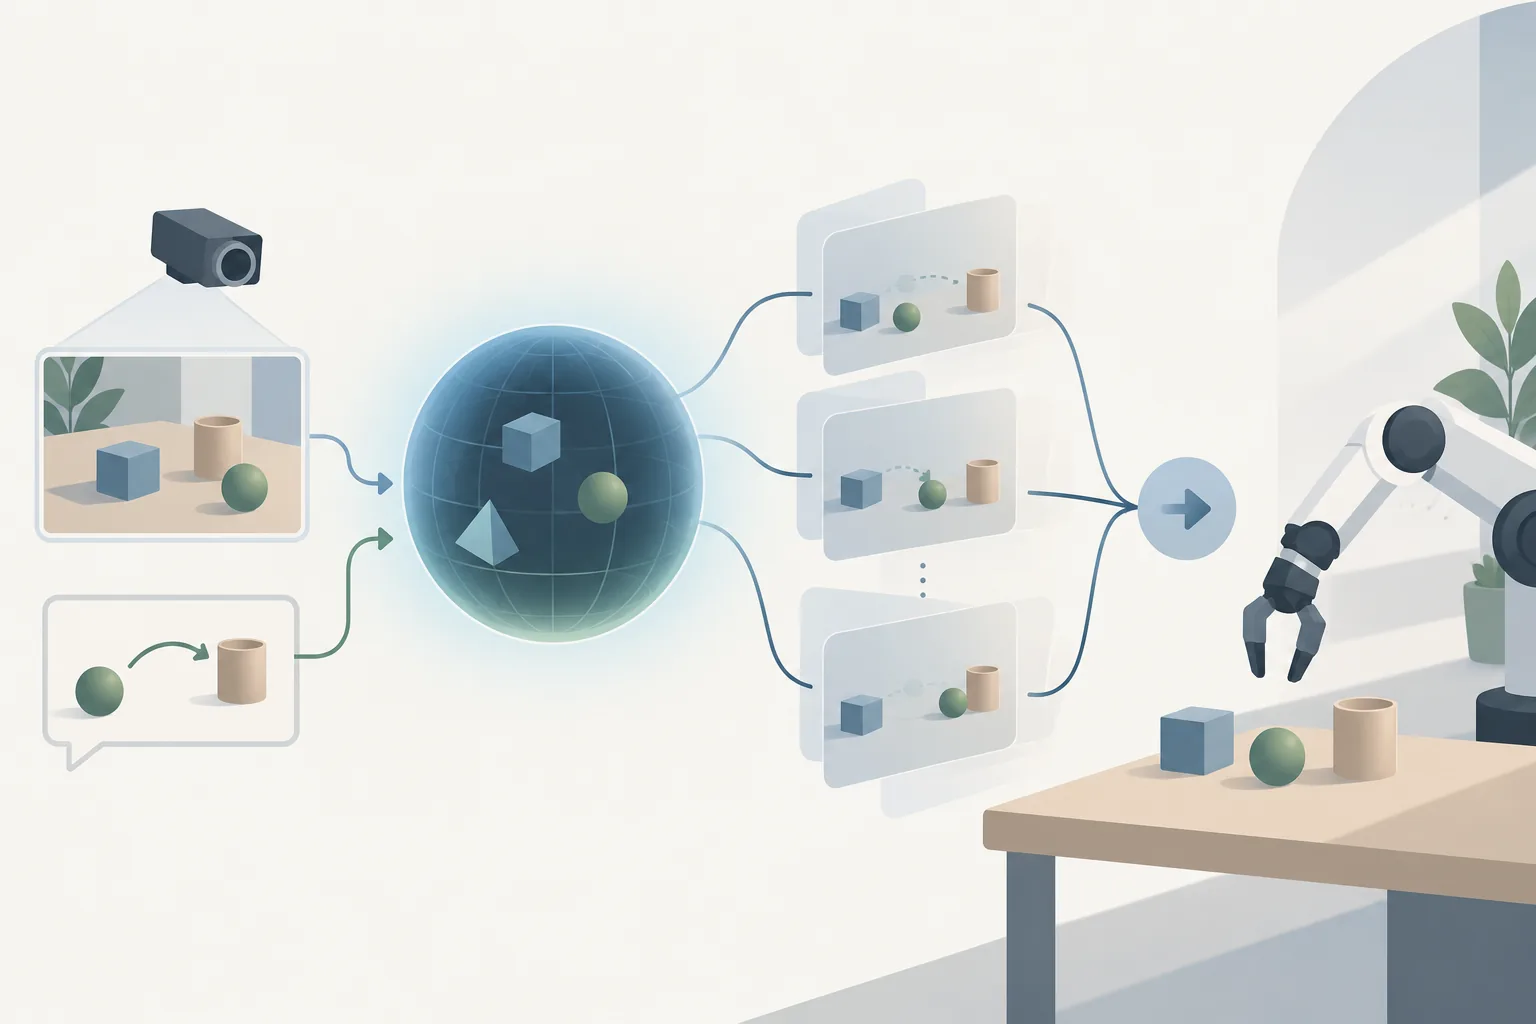
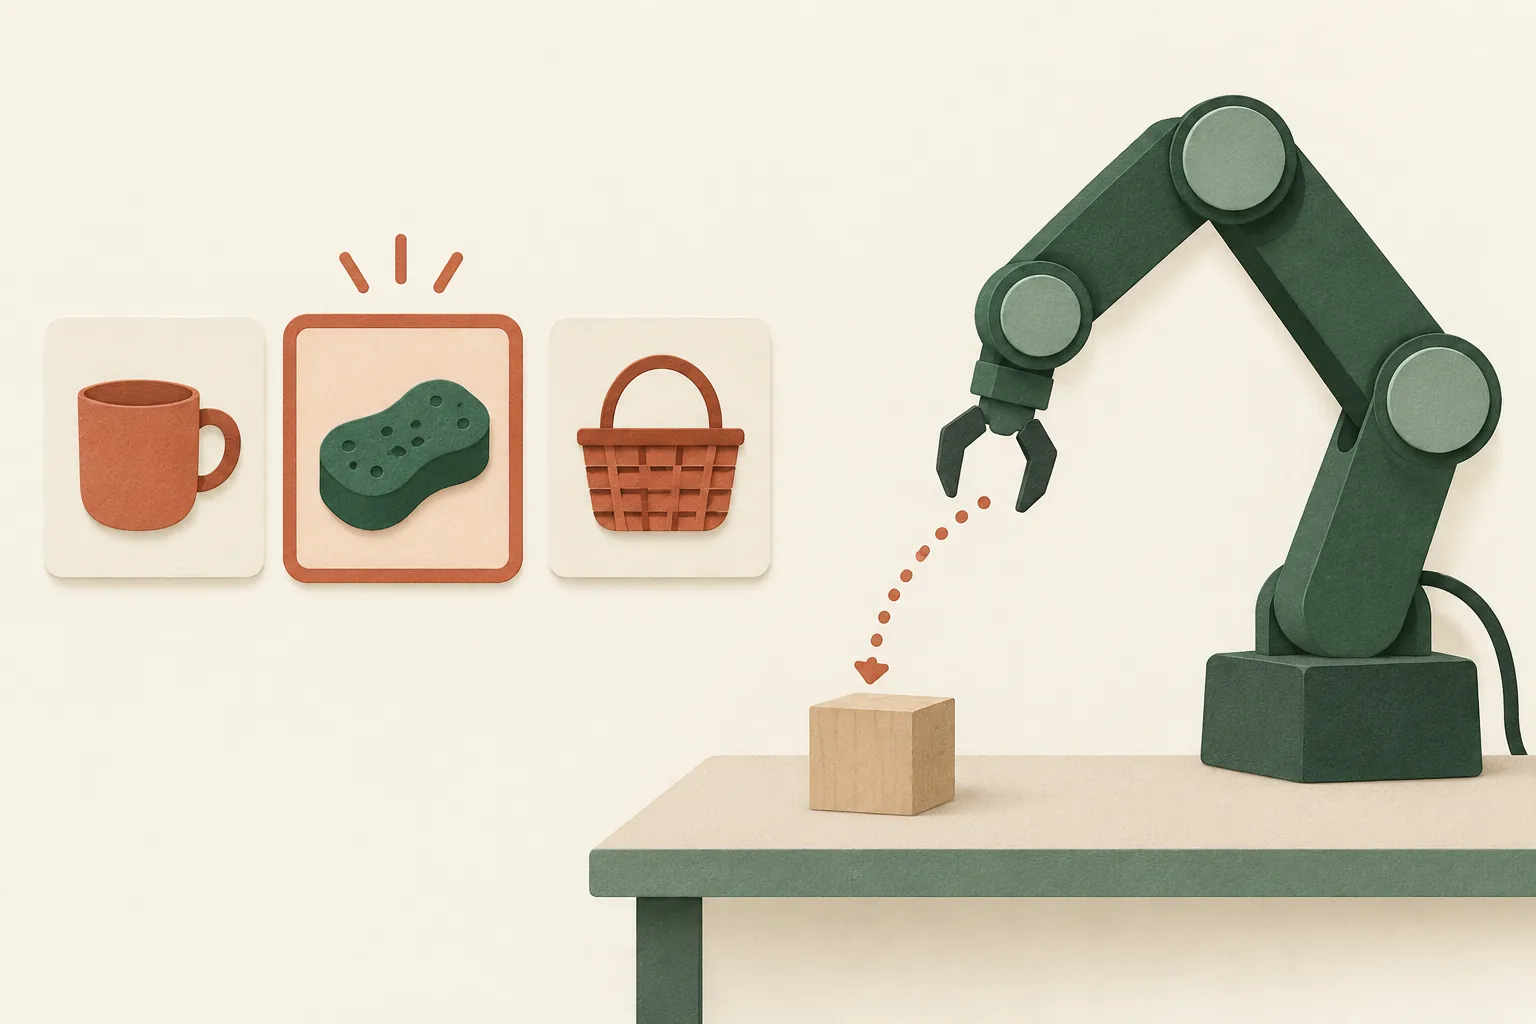
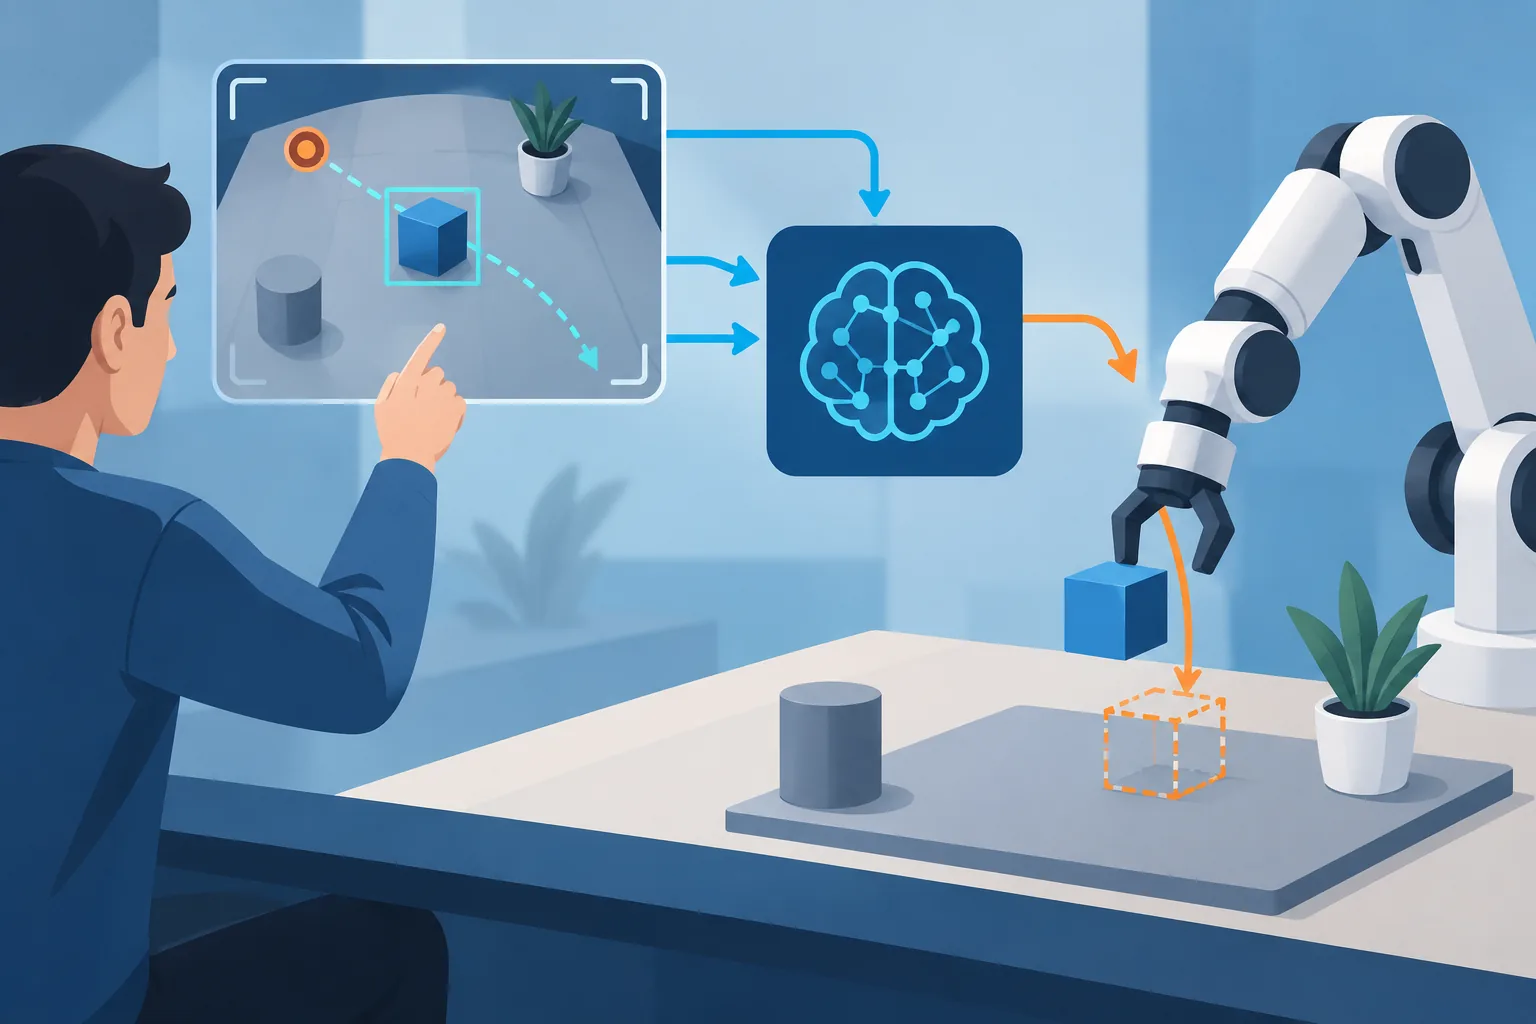
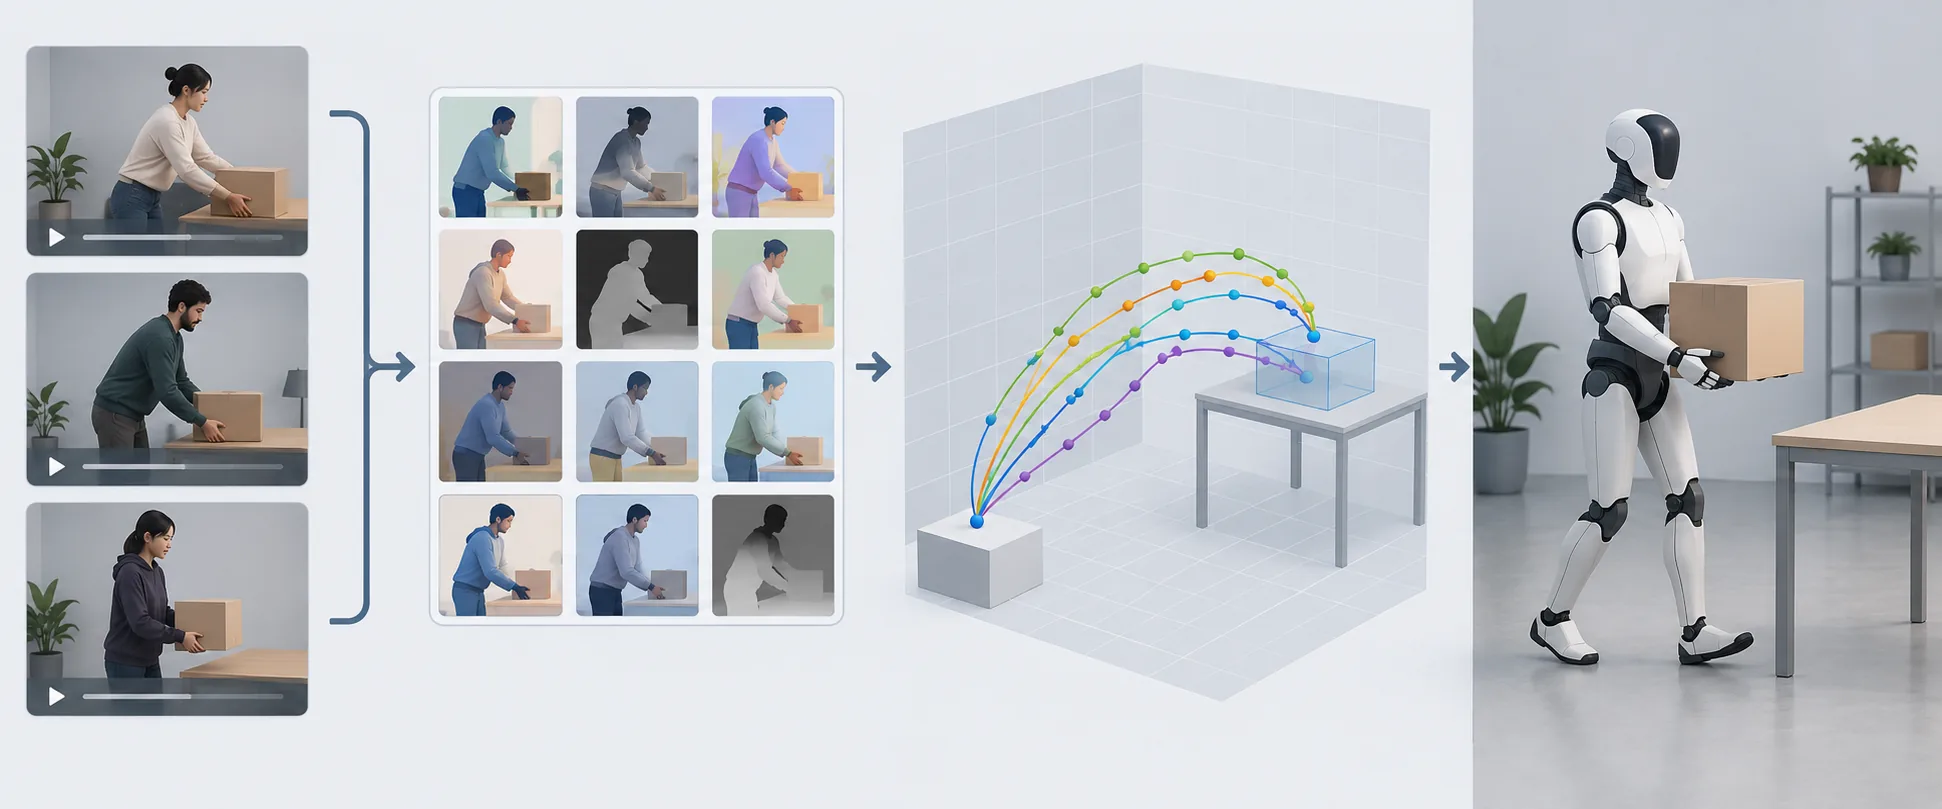
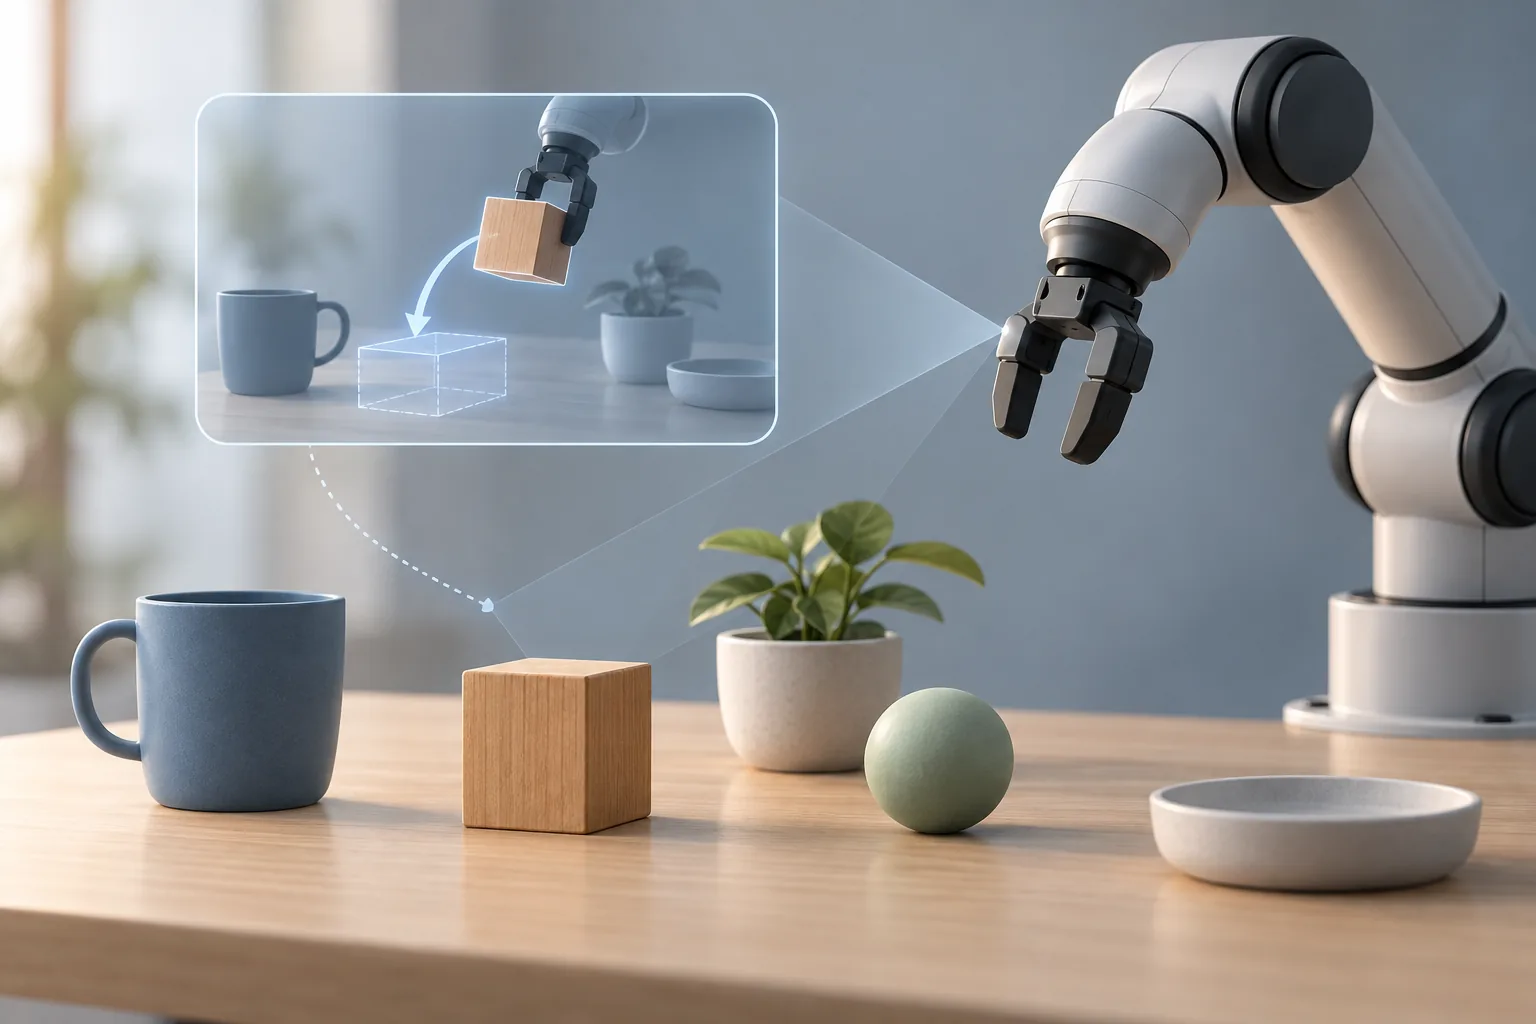
A demonstration is compiled into coordinates describing object motion, contact locations and the desired final scene. It holds that effect program fixed while generating an execution from the live scene, so people can edit the intended outcome and the robot can re-solve the task after changes.
Published