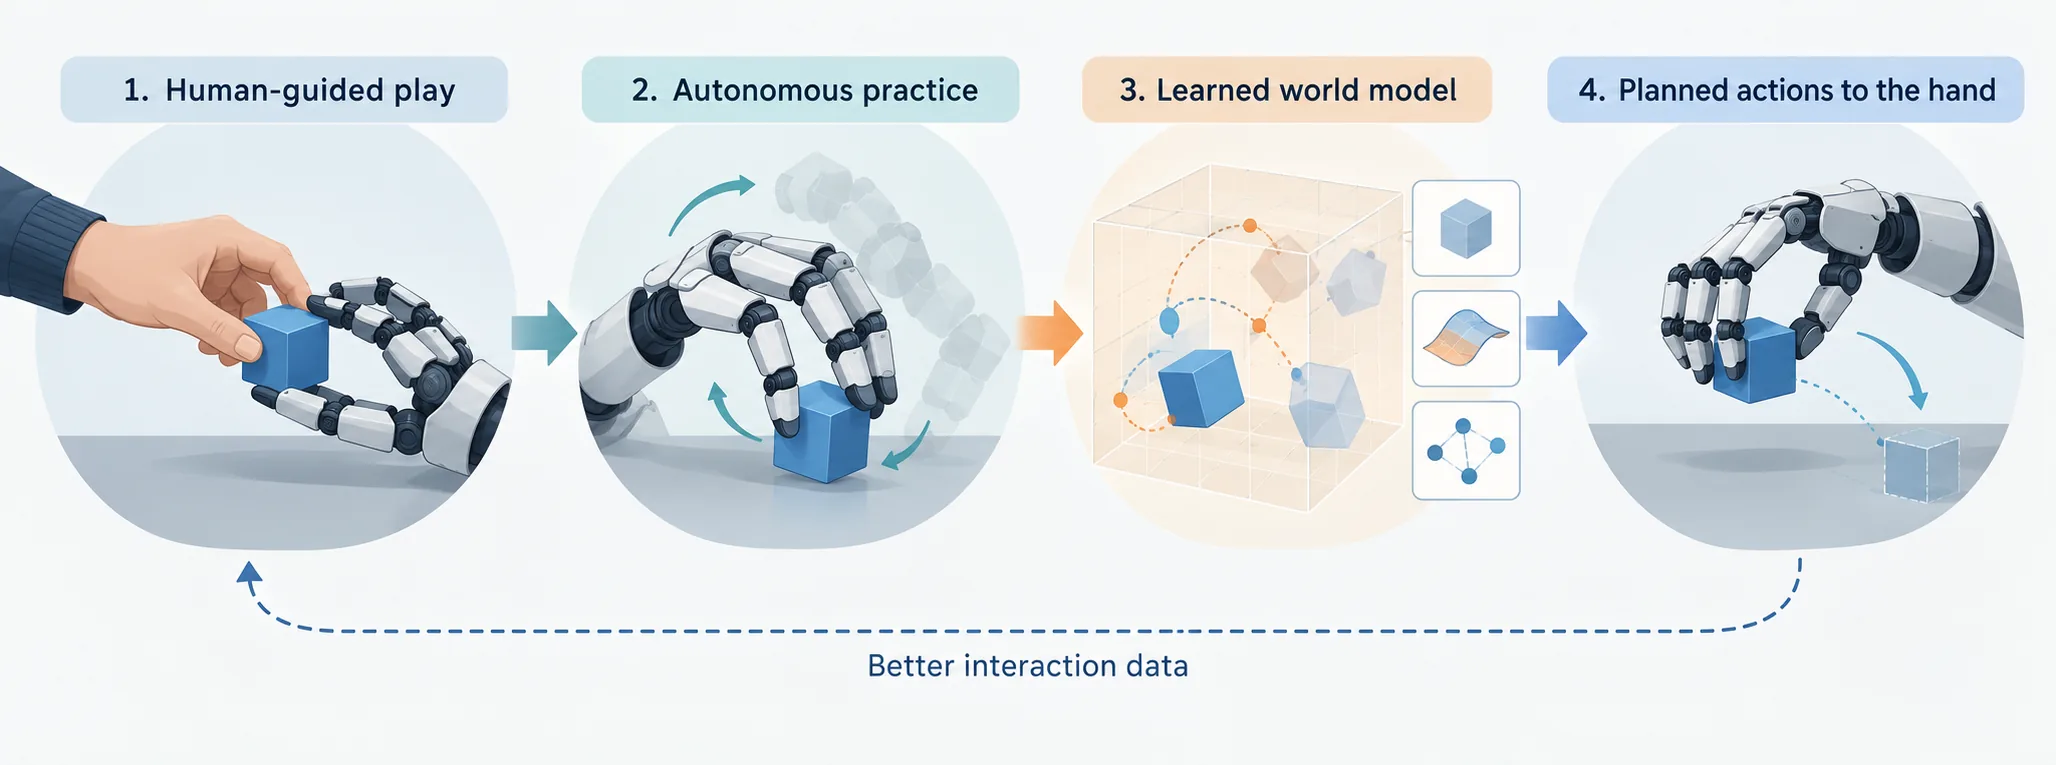
From Guided Play to Autonomous Dexterous Practice
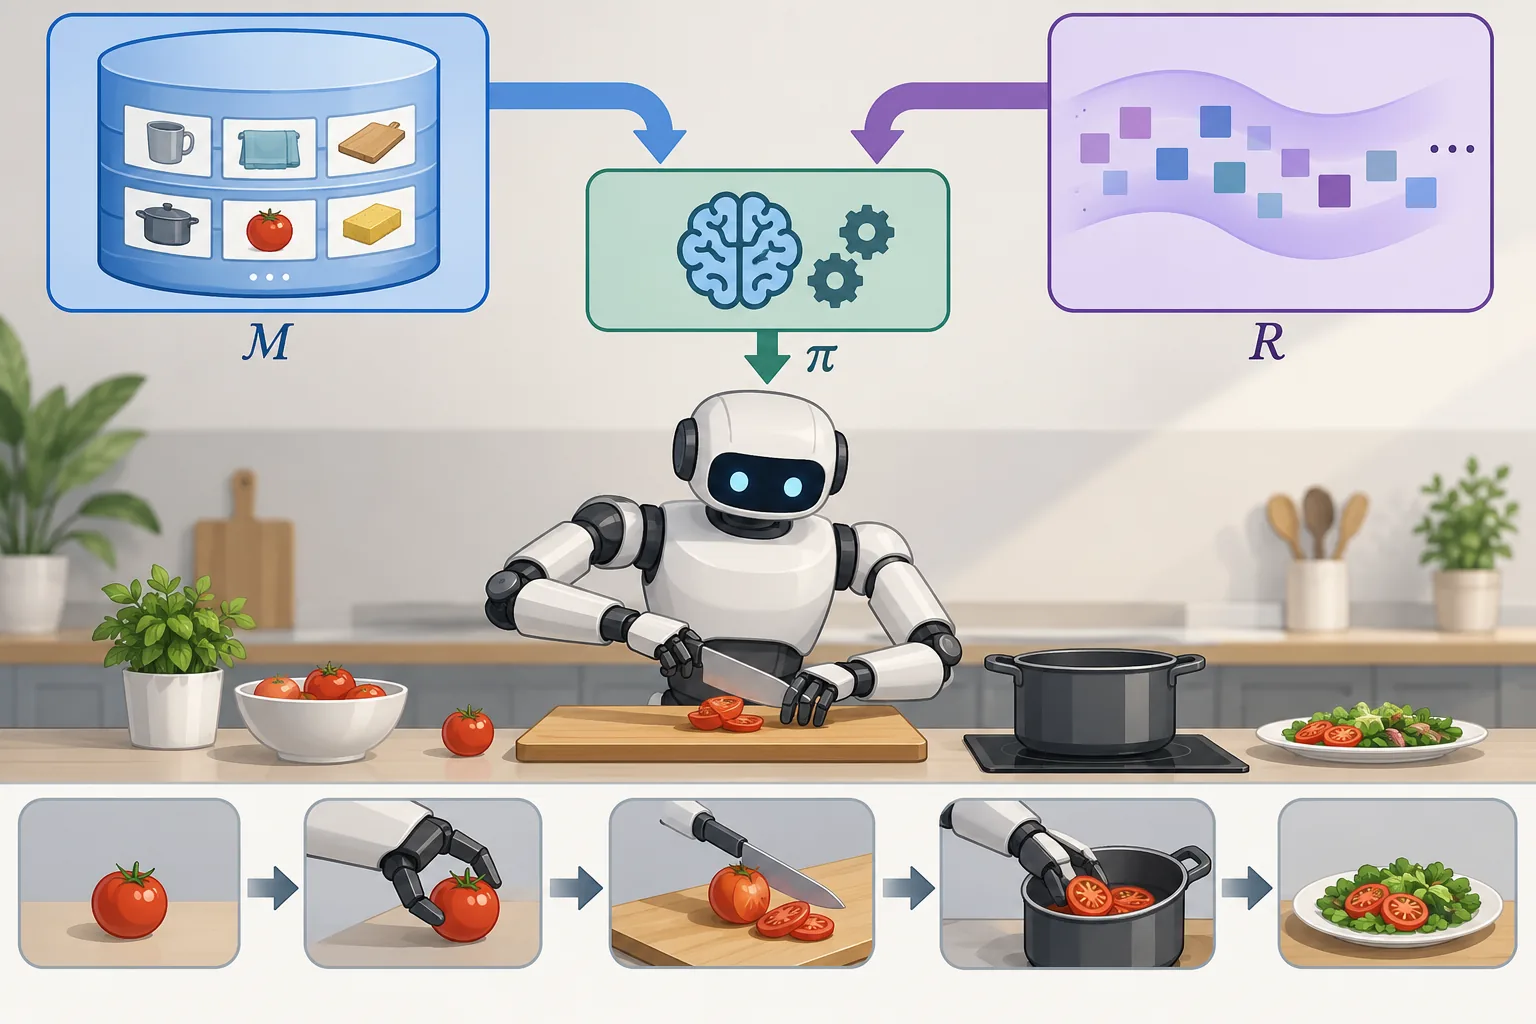
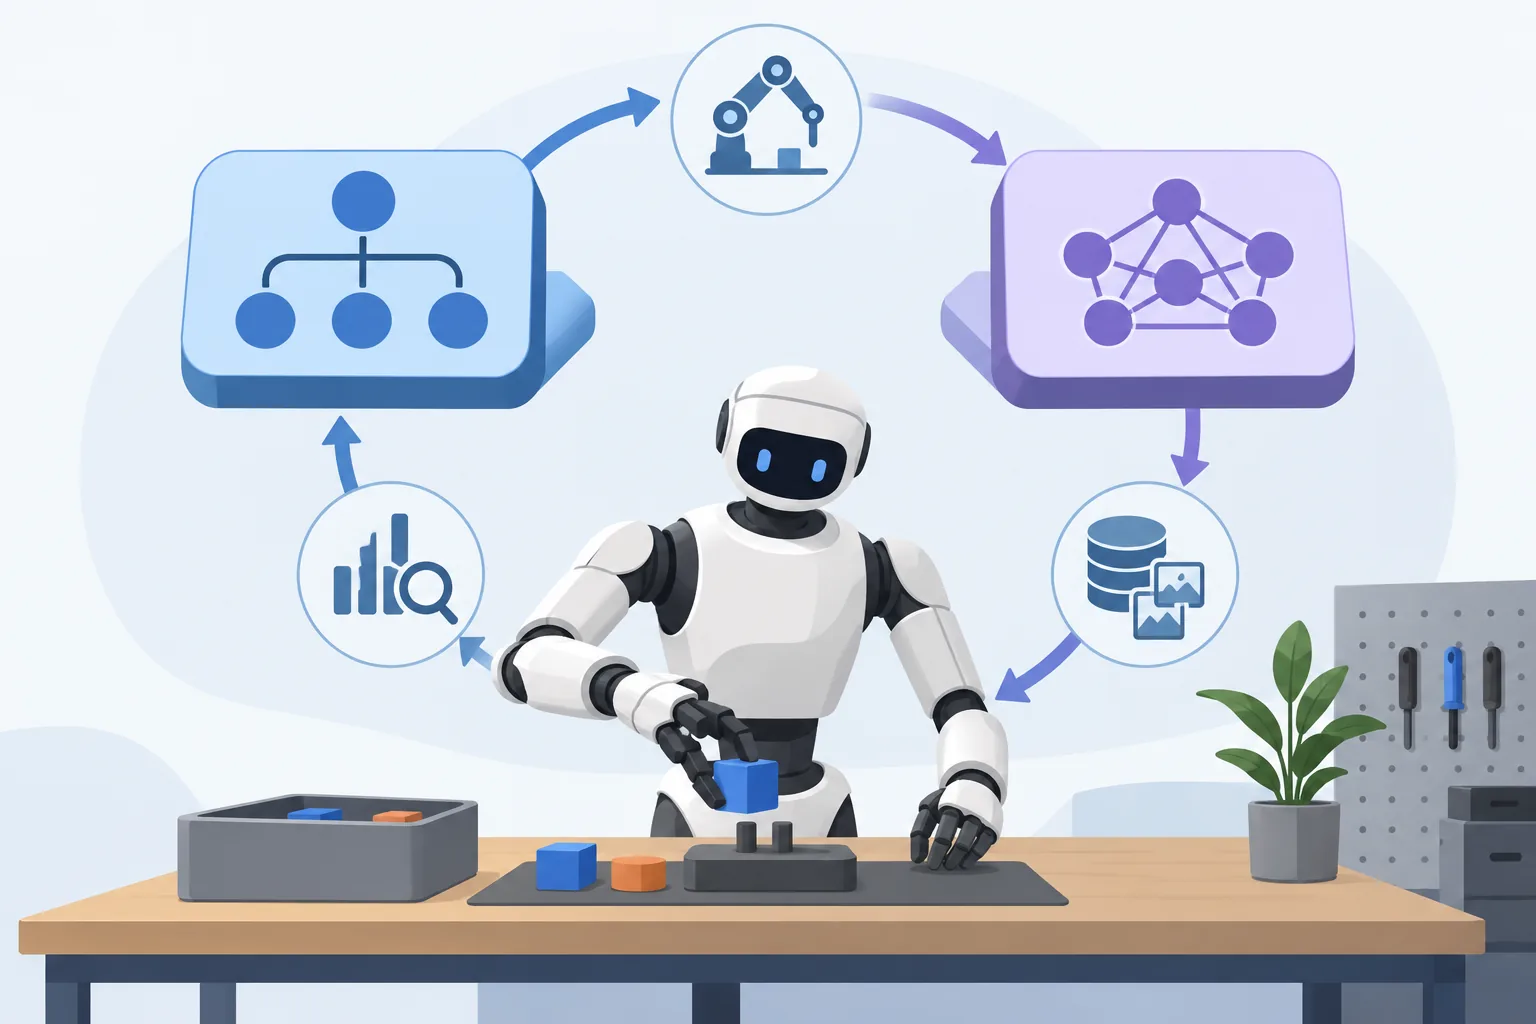
DSP behavior-clones a robot play policy from minutes of human-guided activity, deploys it to collect hours of interaction data, and trains a world model for planning and self-play policy distillation. Its authors report physical-robot results on pushing and in-hand reorientation, including a 69.6% success-rate advantage over hindsight behavior cloning and comparable success to reinforcement learning with 490 times less interaction data.
Published