Learning methods
How Robot-Free Demonstrations Become Force-Reactive Humanoid Skills
The proposed framework divides the job between multimodal policy learning and compliant whole-body control, with results reported in simulation and on three physical tasks.
A trajectory can tell a humanoid where to move, but it does not fully specify how strongly each hand should push during contact. FLORE addresses that gap by recording force information alongside human movement, without using a robot to collect the demonstrations.
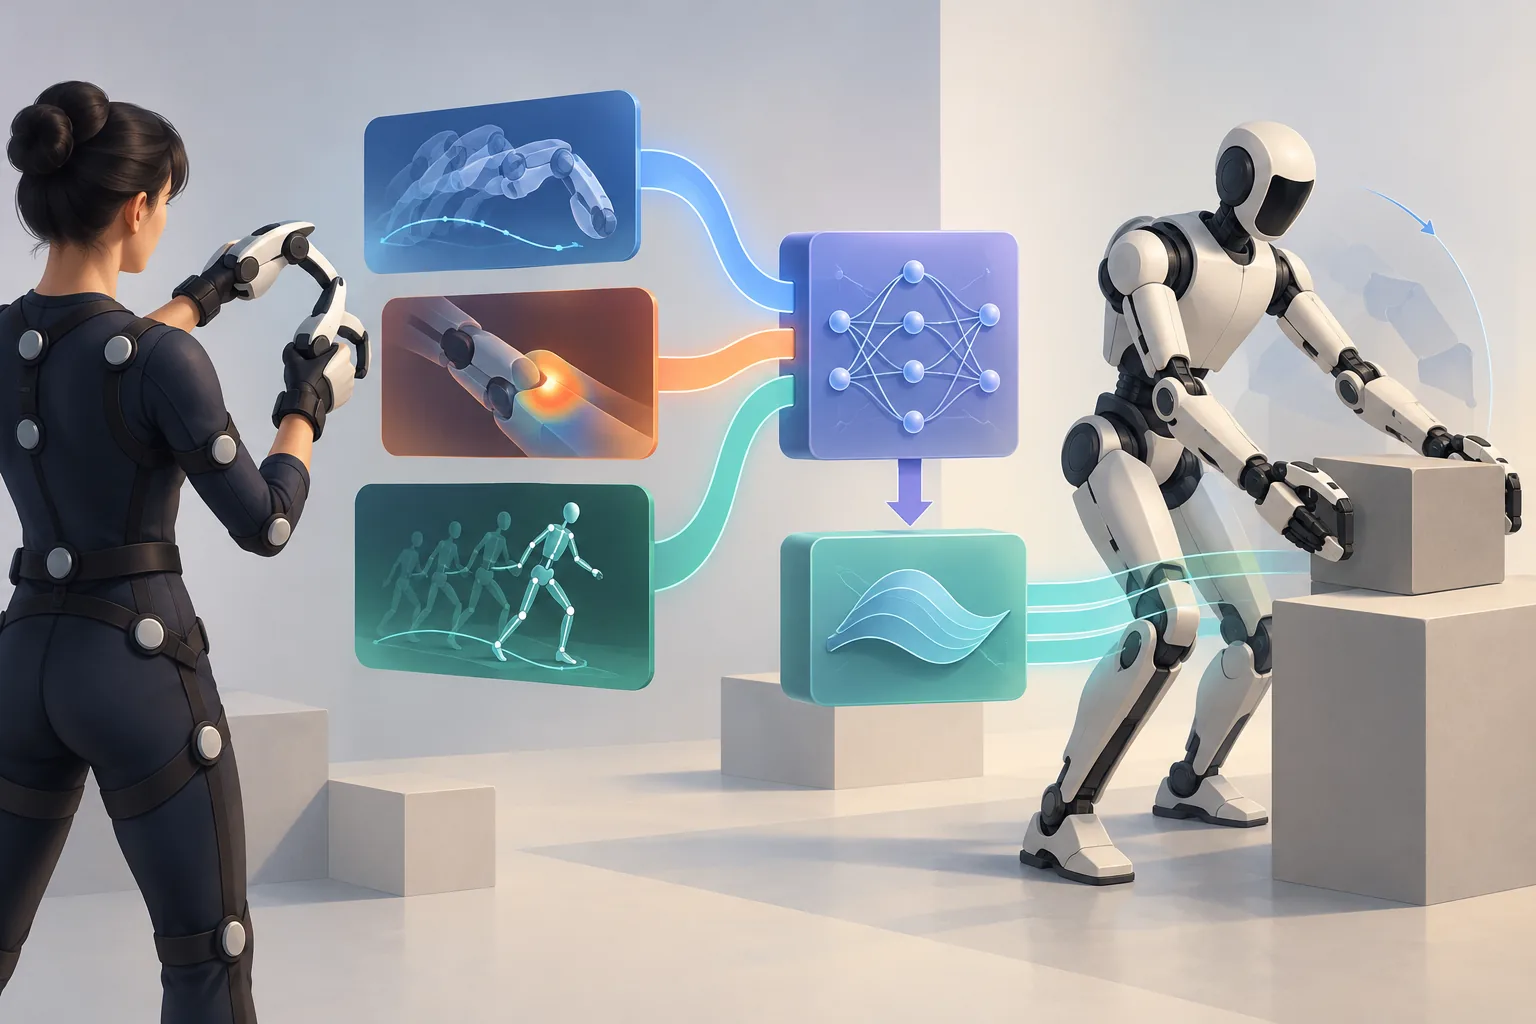
The proposed setup uses two force-sensing UMI-style handheld grippers to capture hand motion and contact wrenches, while wearable trackers record body motion. This gives the learning system paired examples of what the demonstrator did and what contact loads accompanied the movement.
The framework pairs instrumented human demonstrations with a learned policy that predicts actions and per-hand force commands, then uses a force-tracking whole-body controller to execute both while maintaining balance. The diffusion policy receives vision, proprioception and measured wrenches, separating the learned prediction stage from the controller responsible for physical execution.
At each hand, the controller integrates the difference between the commanded force and readings from force/torque sensors. The authors say this lets the hand track force along the commanded direction while remaining compliant along other directions. In their simulation tests, commands of different magnitudes and directions were tracked with little loss of whole-body motion accuracy.
The authors also report an 80% success rate across three contact-rich physical-robot tasks, compared with 26.7% for a position-only policy trained on the same demonstrations and run through the same controller. That controlled comparison supports the value of adding force-reactive predictions in this particular evaluation, but the available evidence is one preprint abstract and does not independently confirm the result or establish broader performance beyond those tasks.