Embodied AI models
AAC Uses Action Entropy to Adapt Chunk Size at Inference Time
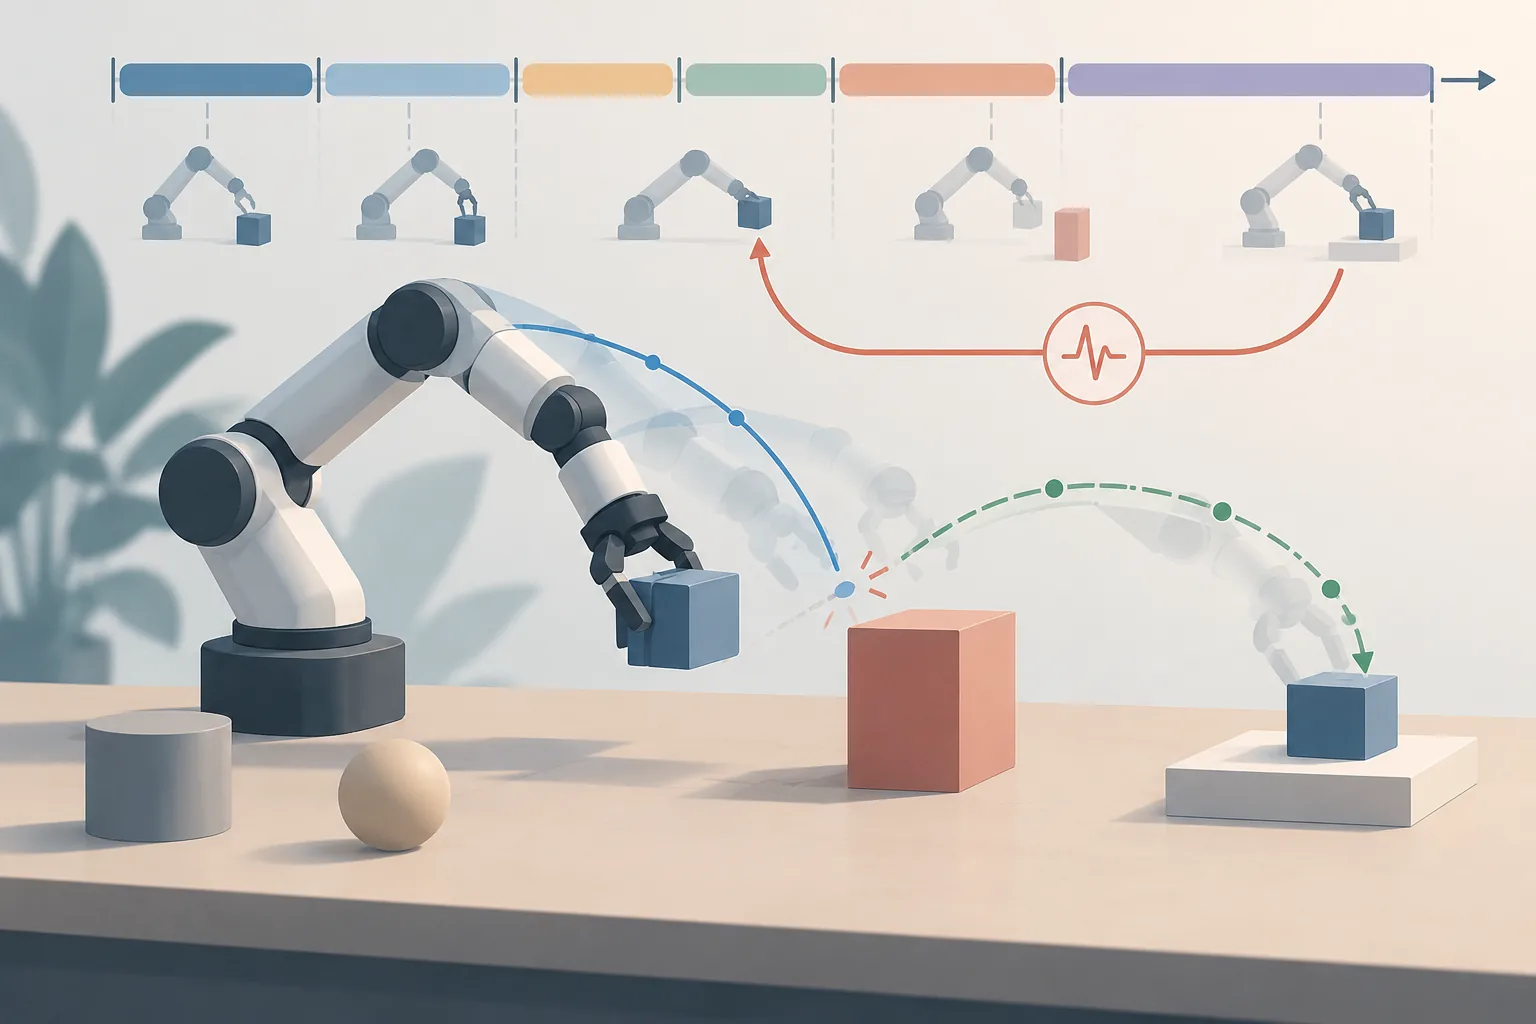
Adaptive Action Chunking uses entropy from a VLA model’s current action predictions to vary how many actions it executes before replanning.
Action chunking allows a vision-language-action model to execute a sequence of predicted actions before planning again. The chunk length sets a control tradeoff: longer sequences reduce opportunities to respond to new information, while shorter ones make discontinuities between successive chunks more likely, potentially producing abrupt shifts between behaviors and jerky motion.
AAC adapts chunk length at inference time by using the action entropy of the model’s current predictions as its selection cue. Instead of applying one empirically chosen length across different manipulation tasks, the strategy determines the chunk size dynamically from that signal. The available abstract does not explain how particular entropy values map to particular lengths, so the exact selection rule cannot be reconstructed from this evidence alone.
The preprint’s authors report extensive experiments across simulated and real-world robotic manipulation tasks and claim substantial improvements over state-of-the-art alternatives. However, the abstract supplies no task-level results, numerical metrics or comparison details, and the dossier contains no independent validation. It therefore supports the proposed mechanism and its intended responsiveness-versus-continuity tradeoff, but not a quantitative assessment of the reported performance gains.