Reliability and safety
When a Robot’s Body Calls for a Different Strategy
A proposed framework uses joint state, recent statistics and execution history to reconsider how a manipulation goal should be completed without replacing its low-level controller.
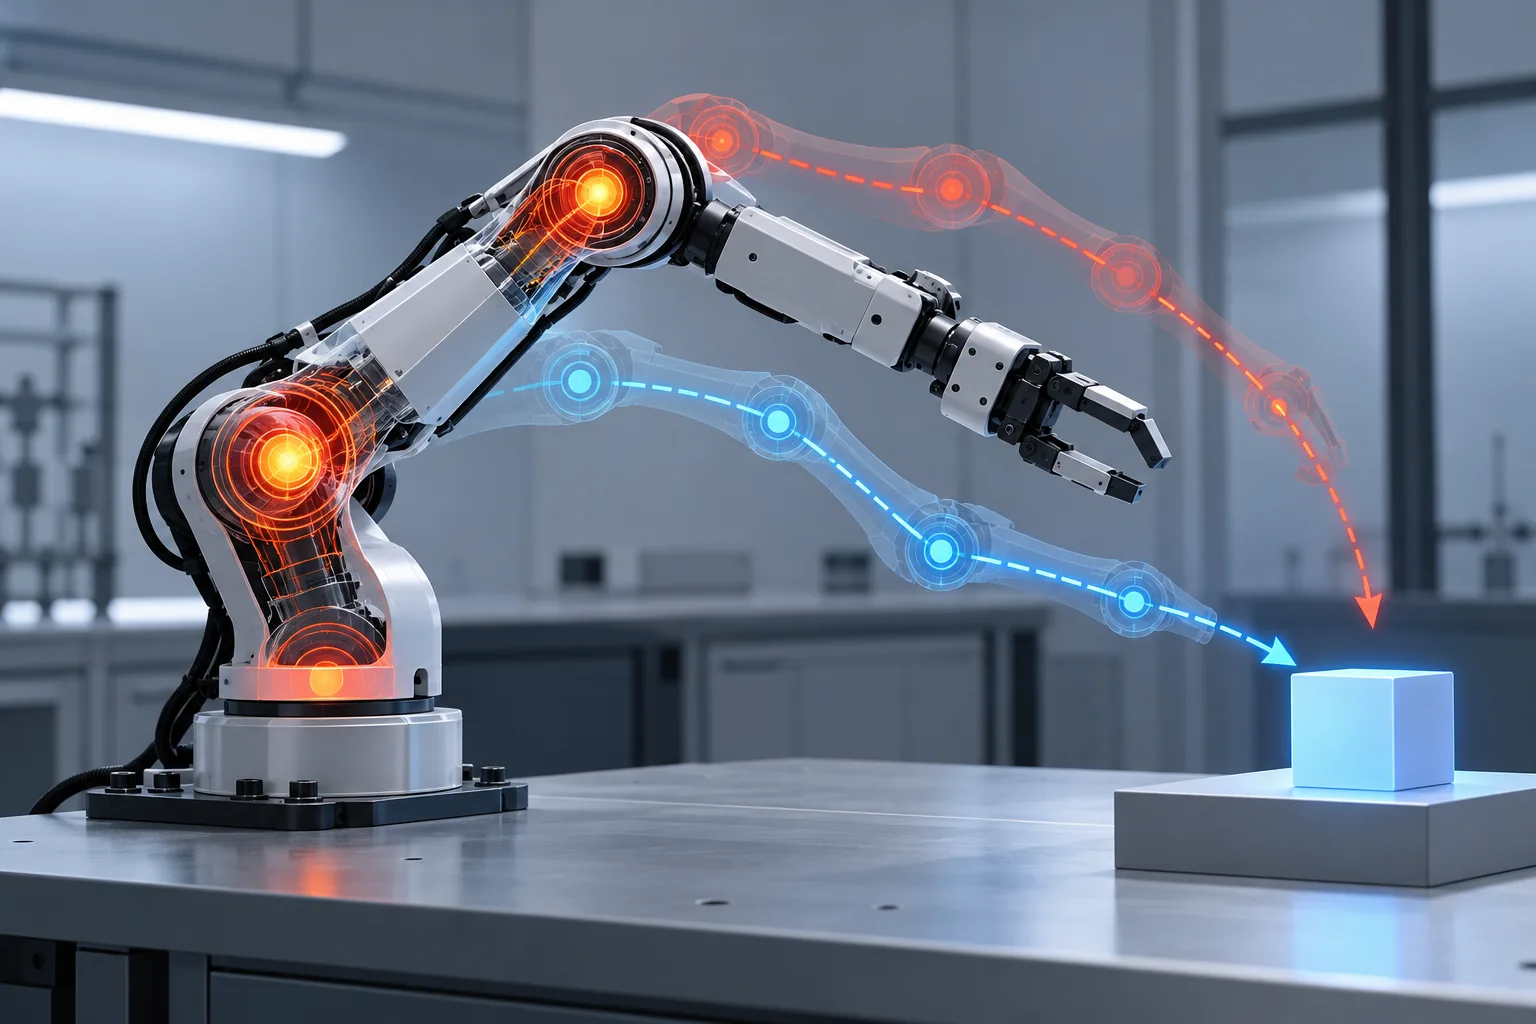
A robot can use a body-state event, such as increased joint load or limited mobility, to trigger high-level replanning and choose a context-dependent manipulation strategy. In the proposed framework, a large language model interprets joint-level state, recent execution statistics and execution history to select the alternative, while the task objective and low-level controller remain unchanged.
This distinction matters because a strategy may remain geometrically feasible while becoming physically unsuitable because of increased joint load or limited mobility. Incorporating the robot’s condition into strategy selection therefore lets the system consider physical effort and suitability instead of treating task success as the only relevant signal.
The authors evaluated the approach on reaching under controlled load and asymmetric mobility constraints, both in simulation and on a real robot. They report high task success alongside reduced physical effort and more efficient strategy adaptation, and describe additional contact-rich manipulation experiments using the same interface. These results come from a single preprint abstract, which provides no numerical measurements or detailed comparisons, so the reported benefits and applicability are not independently confirmed here.