Data and benchmarks
How One Robot Dataset Represents RGB and Depth
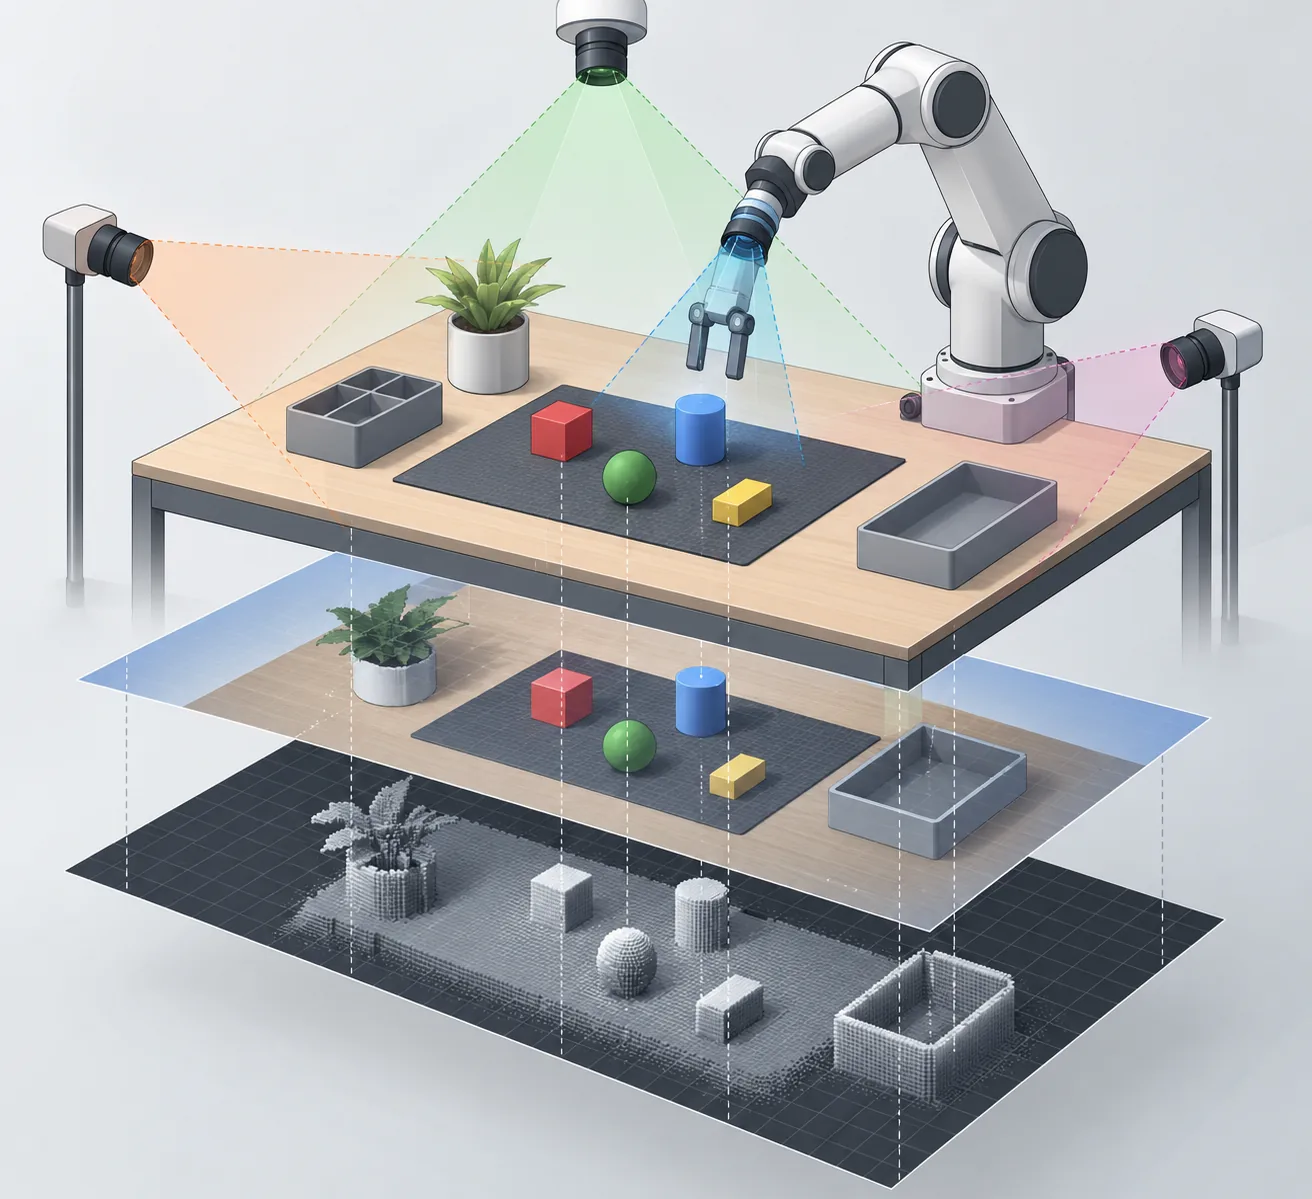
The LeRobot demo dataset documents RGB observations by shape, type, range, and camera resolution, and linear depth by meaning, shape, type, range, and replay encoding.
In the documented LeRobot demo dataset, RGB observations are four-channel numpy.uint8 image arrays, while linear-depth observations are two-dimensional numpy.float32 distance arrays in meters.
The dataset page describes each RGB frame as a camera-perspective view of the scene with shape (height, width, 4) and values from 0 to 255. Head-camera images have a resolution of 720 × 720, while wrist-camera images are 480 × 480.
Linear depth records the distance from the camera to scene geometry, with values proportional to physical distance. Each observation has shape (height, width), uses numpy.float32, and covers a stated range of 0 to 10 meters. The source says depth videos are log-quantized during replay and then dequantized into metric depth values.
These specifications apply to this particular dataset rather than establishing a universal representation for robot demonstrations.